

3DMakerPro Raven Review: The €1599 LiDAR Scanner — Specs, pricing and comparison
The handheld LiDAR scanner market just got a lot more interesting. 3DMakerPro has officially launched the Raven, and with an early-bird price starting at €1229+VAT, it is vastly outperforming any other standalone LiDAR/SLAM scanner on the market. But a low price only counts if the hardware is up to the task.
Here is an in-depth analysis of the Raven's specifications and positioning within the 3DMakerPro lineup. We compare its positioning with competition from FJD Trion, SHARE, and others. We also analyze what the community is already flagging as potential issues.
What is the 3DMakerPro Raven?
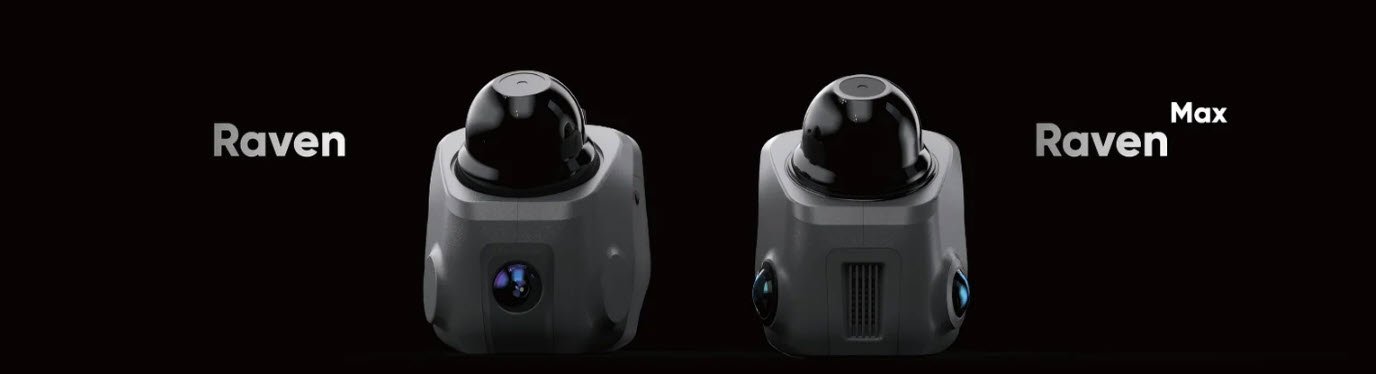
The Raven is 3DMakerPro's entry-level spatial LiDAR scanner. It is a smaller, lighter, and significantly cheaper alternative to the current Eagle (launched in early 2025) and the professional-grade Hawk.
Considering 3DMakerPro's progress from structured-light object scanners (Mole, Seal, Moose) into the spatial LiDAR territory with the Eagle, the Raven is the logical next step. The goal is to bring autonomous handheld LiDAR scanning to an affordable price point, allowing hobbyists, content creators, and small businesses to realistically justify the purchase.
The device was first spotted at Formnext 2024. Early hands-on impressions made it look like a compact version of the Hawk, featuring an RTK expansion slot, a touchscreen, and a target price of $999. These initial details have now been confirmed by the official spec sheet. The price brackets match what is reported on the 3DMakerPro store page.
For those unfamiliar with the 3DMakerPro scanning workflow, the videos on the Eagle scanner offer a good overview of the RayStudio software pipeline. They demonstrate the scanning process and the general output quality you can expect. The Raven shares the same software ecosystem and output formats. These tutorials therefore provide context directly relevant to the user experience of the Raven.
3DMakerPro Raven Specifications
From the spec sheet published by 3DMakerPro:
Accuracy: 2 cm at 10 m, 3 cm at 20 m, 5 cm at 40 m
LiDAR Detection Range: 40 m at 10% reflectivity / 50 m at 80% reflectivity
Maximum Scan Coverage: 80–100 m (Note: 3DMakerPro lists this as "scan range" — see explanation below)
Field of View: 360° horizontal × 40° vertical
Point Cloud Frequency: 150,000 pts/sec
Laser: 905 nm, Class 1 eye-safe (IEC60825-1:2014)
Camera: 12 MP, 1 camera (or 2-camera system for the MAX version)
HDR Mode: No
Screen: 3.9" AMOLED
Battery: 12,000 mAh — approx. 2 hours of work, supports external power while charging
Weight: 1.1 kg
Dimensions: 148 × 288 × 98 mm
Built-in Processing: 8 core, 2.4 GHz, 32 GB storage (expandable via TF card)
Data Interface: USB-C ×1
Power Supply: USB-C ×1
Network: Wi-Fi 5
Output Formats: 3D color point cloud PLY, 3D Gaussian splatting PLY, 3D colored polygonal model OBJ
Expansion: RTK expansion kit, Insta360 X4/X5 expansion kit, various accessories
A note on "Scan Range" and "Scanning Radius" in the 3DMakerPro Raven: read this before comparing
This is a detail that can cause confusion when comparing LiDAR scanners and it is worth clarifying. 3DMakerPro uses two distinct specifications that look similar but mean different things: "Scan range" is the LiDAR detection distance. It indicates the distance at which the laser can detect a surface from the device. "Scan coverage" is approximately the total coverage diameter, about twice the range. When 3DMakerPro states that the Eagle has a "140m scan range," this corresponds to a 70m detection range.
FJD Trion, SHARE, and Livox all specify "scan range" as the detection distance, equivalent to what 3DMakerPro calls "detection range." A direct comparison between 3DMakerPro's "140m range" and FJD's "70m range" is therefore misleading. They actually describe the same sensor capability. Every comparison in this article uses the consistent metric of LiDAR detection range, i.e., the distance reached by the sensor at 80% surface reflectivity, unless otherwise indicated.
3DMakerPro Raven Pricing
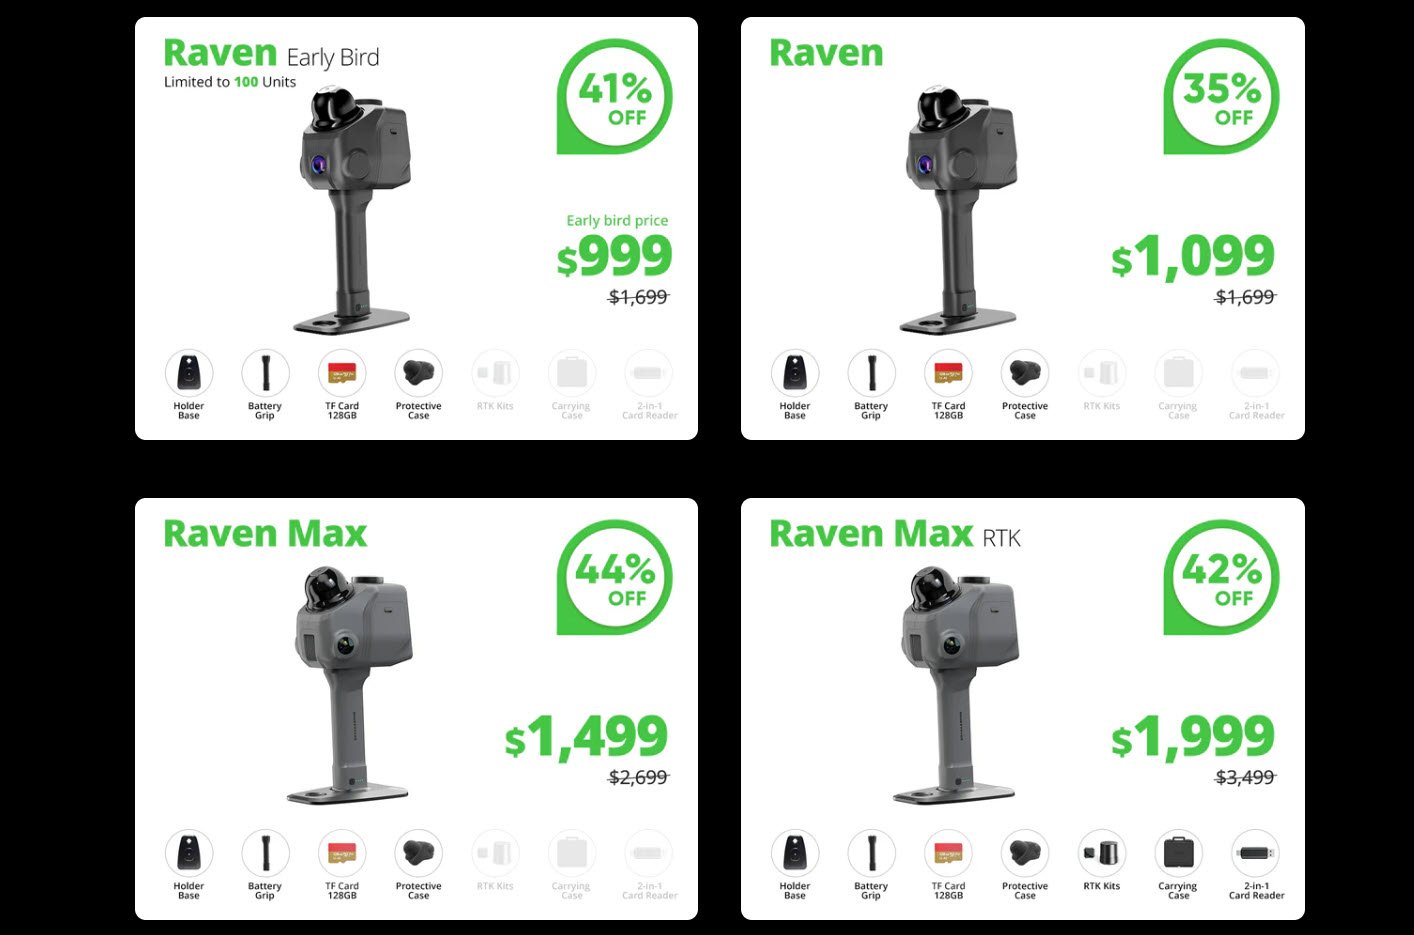
This is where the Raven comes in. At launch, four configurations are available at discounted prices:
Raven vs Eagle vs Hawk vs FJD Trion vs SHARE: Full Comparison
Here is the comparison between current handheld LiDAR/SLAM scanners. All LiDAR range values use a detection distance at 80% reflectivity for a consistent comparison. For details, see the note on scan range vs. radius above.
| Specs | Raven | Eagle | Hawk | FJD P2 | FJD V4e | SHARE S20 SE | SHARE C1 |
| Accuracy | 2 cm at 10 m | 2 cm at 10 m | 1.5 cm at 10 m | 1.2 cm pole | 3 cm pole | ≤1cm rel. | <1cm |
| LiDAR Range* | 50 meters | 70 meters | 70 meters | 70 meters | 50 meters | 70 meters | 70 meters |
| Points/sec | 150k | 200k | 480k | 200k | 154k | 200k | 200k |
| Vertical FOV | 40° | 59° | 63.5° | 59° | ~70° | 59° | ~59° |
| Camera | 12 MP (1-2) | 48 MP (1-4) | 13 MP 1" | 2x12MP | Phone | 2x2.3 MP | Dual wide |
| HDR | NO | 8K HDR | YES | NO | NO | NO | NO |
| Weight | 1.1 kg | 1.5 kg | ~0.9 kg | 0.7 kg | 0.89 kg | 0.955 kg | ~0.575 kg |
| Battery | ~2 hours | ~1 hour | ~1 hour swap | ~4 hours | 5+ hours | ~3 hours | ~3 hours |
| RTK | Optional | Optional | Built-in | Optional | Built-in | Optional | NO |
| Standalone | YES | YES | YES | YES | No (phone) | No (phone) | No (phone) |
| Gauss. Splat | YES | YES | YES | YES | YES | YES | Coming soon |
| Price | $999-1,999 | ~$3,399+ | ~$8,999+ | ~$4,000+ | ~$4,299 | ~$4,499+ | $3,999 (KS) |
*LiDAR Range = detection distance at 80% surface reflectivity. 3DMakerPro markets the Eagle with a "140m scan range" and the Raven with a "100m scan range." These figures represent the total coverage diameter, about twice the detection distance. They are therefore not comparable to the "scan range" specs of FJD or SHARE. This table uses the consistent detection distance metric.
Understanding the LiDAR sensor: why it matters
The community is paying close attention to the LiDAR sensor used by the Raven, and for good reason. It is arguably the most important component in any SLAM scanner.
The Livox Mid-360 has become the de facto standard sensor in this class of handheld SLAM scanners. Manufactured by Livox, a subsidiary of DJI, it is a compact unit with a 360° × 59° field of view. It offers 200,000 points per second and a proven detection range of 70m at 80% reflectivity.
Of critical importance is its broad support for the SLAM algorithm in the open-source robotics community. It includes Livox's LIO-Livox odometry system. It also boasts a solid track record in professional surveying and mapping applications. Numerous academic studies have validated its geometric accuracy. According to 3DMakerPro's specifications, the Eagle uses this class of sensor. The FJD Trion P1 and P2 use sensors with matching specs: 200,000 pts/s, 360° × 59° FOV, and 70m range. SHARE has confirmed that the S20/S20 SE uses the Mid-360 directly, as documented on the Livox showcase page.
The published specs of the Raven – 150,000 pts/s, 360° × 40° vertical field of view, 50m detection range – clearly indicate that it does not use a Livox Mid-360. The narrower vertical field of view, 40° vs 59°, is the most significant practical difference. It means the Raven captures less environmental detail per pass, particularly on the vertical axis. Scanning tall structures will require more overlapping passes and additional time. Capturing ceilings in indoor scans or working in confined spaces will also require more passes. The lower point density, 150k vs 200k, translates to a slightly lower level of detail per second. This limitation is nonetheless less significant than the reduction in field of view.
This is not necessarily a deal-breaker, given that it is thanks to a cheaper sensor that 3DMakerPro achieves the $999 price point. However, it is an important compromise that you should understand before purchasing.
The LiDAR sensor directly affects point cloud density and SLAM drift resistance. It also affects scanning reliability in difficult environments. Community members in 3DMakerPro's Raven and Eagle Facebook groups have flagged this as their primary concern. This is a legitimate concern.
3DMakerPro has not publicly disclosed the manufacturer or model of the Raven's sensor (at least as far as I am aware).
A further gap is represented by the missing IMU specifications. The IMU, or inertial measurement unit, is fundamental for SLAM stability and drift control. This is particularly true in featureless environments, such as long corridors, open fields, or tunnels.
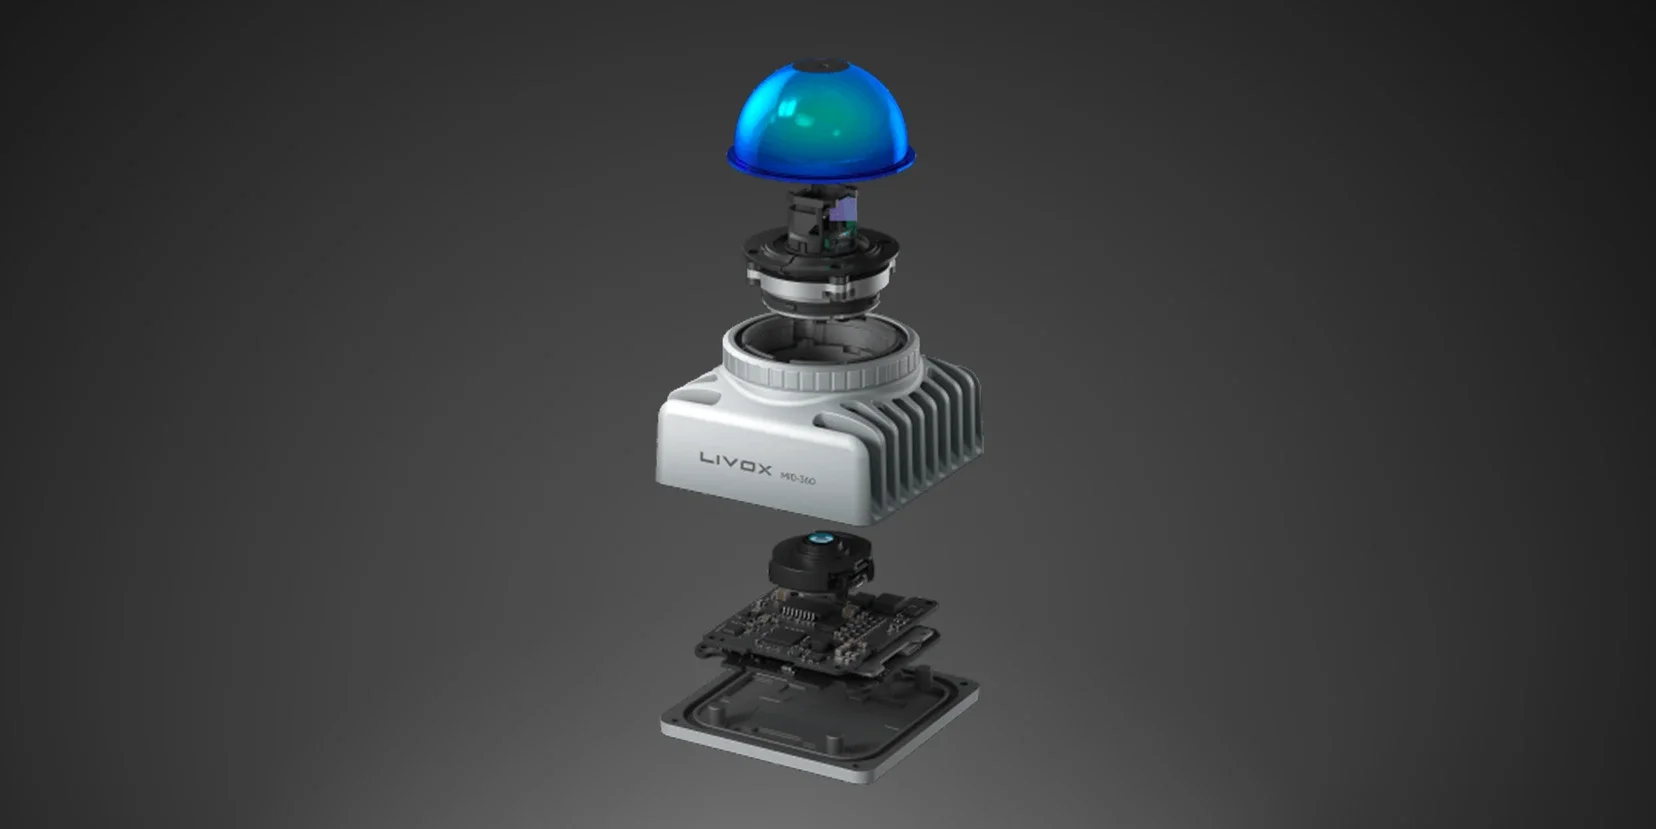
Livox Mid-360 sensor module.
What distinguishes 3DMakerPro Raven
The price is truly disruptive. At a price between $999 and $1,099 for the base Raven, you get an autonomous LiDAR scanner with an AMOLED touchscreen, built-in processing, and Gaussian splatting output. You don't need a phone while scanning. You don't even need a laptop or tethering. The FJD Trion V4e LiDAR kit is the closest competitor at an economic level in the handheld SLAM scanner market. However, it requires an iPhone 15+ and costs over $4,000, currently $4,299 on sale from $4,799. SHARE C1 targets a similar prosumer audience via Kickstarter. However, the final retail price and delivery times have not yet been defined.
Two hours of battery life is a significant advantage compared to the approximately one hour of the Eagle, according to 3DMakerPro's specifications, which indicate 60 minutes for the Eagle. You can realistically scan an entire building, both indoors and outdoors, without needing a power bank. Raven also supports external power during scanning, a handy feature if you accidentally leave it discharged.
Insta360 X4/X5 and RTK expansion allows Raven to adapt to more use cases. Those interested in managing their workflows using Insta360 for Gaussian splatting and RTK/PPK have custom upgrade paths. I appreciate how this approach keeps entry costs low. At the same time, it leaves room for more professional workflows.
It is completely autonomous. Unlike the FJD V4e, which requires an iPhone 15+, and the FJD P2, which needs a smartphone or tablet for real-time monitoring via the FJD Trion Scan app, Raven operates completely independently. The SHARE S20/C1 line, on the other hand, requires the SHARE Capture app. Raven is autonomous thanks to its integrated 3.9" AMOLED screen and internal memory. For field use in remote locations, this is critical. It is equally important for users who want a simpler, more immediate workflow.
Where the concerns are
The LiDAR sensor is a clear step backward compared to the competition. As described above, the Raven's 150,000 points/s, 40° vertical field of view, and 50m detection range place it below all other LiDAR scanners in this comparison. The narrower vertical coverage means more scanning passes in complex environments. It can also cause a potentially weaker SLAM lock in spaces with vertical variations.
Community members in the 3DMakerPro Raven and Eagle Facebook user groups have openly expressed this concern. The sensor appears to be a lower-quality unit, intended for low-end applications. For workflows where laser performance is more important than the camera, this is a clear compromise.
No published IMU specifications. The IMU is essential for SLAM stability and drift control, and experienced users have pointed out its absence. But this means they aren't using one (or it's just not very effective)—who knows.
3DMakerPro's software track record is not the best. Having spent a lot of time with the Eagle Max and RayStudio, this is one area where expectations must be realistic. Eagle launched in early 2025 with an ambitious software roadmap. Gaussian Splatting processing was planned for April 10, 2025. Point cloud mesh creation was planned for April 15. Panoramic image stitching was planned for April 30, according to 3DMakerPro's RayStudio tutorial page. In practice, features arrived much later than expected. Independent reviews, including a detailed test from 3Printr.com, have consistently described RayStudio as functional but not yet mature.
Stability issues, particularly on macOS, have been widely documented. The post-processing workflow still requires patience. The software has improved over the last year, but it has been a slow process. Since Raven shares the same software ecosystem, we should expect a similar trajectory. We cannot yet speak of a fully refined "beta-tester" experience.
Let's just hope Eagle and Hawk have made the progress needed to make Raven a better launch!

Philipp Kreiser (PrinterForFun) expresses skepticism regarding the Lidar sensor and initial scanning.
RTK = real-time or just post-processing? The issue remains quite confusing regarding the 3DMakerPro product line. The official Eagle FAQ describes RTK as Real-Time Kinematic positioning. However, the RayStudio workflow tutorial on the 3DMakerPro blog shows that RTK data is applied as a post-processing step. It actually indicates to "select the RTK option in the processing steps."
Reports from community members are mixed. Some doubt that true real-time RTK correction works reliably. The suspicion remains that it is effectively PPK, i.e., Post-Processed Kinematic.
If georeferenced accuracy is important to your workflow, it's worth verifying this with real user reviews. I hope to provide you with a review unit before you commit to the Raven RTK kit.
For comparison, both the FJD Trion line and the SHARE S20 RTK offer well-documented real-time RTK workflows. They also have proven accuracy specifications, but at quite different price points.
The first scan samples were not impressive. The presentation video by Philipp Kreiser, PrintedForFun / 3D Scanning Users Group, highlighted that the first published Raven scans did not look particularly convincing. Pre-release hardware will improve with firmware and software updates. However, at the moment, limited independent scan data is available to evaluate real-world performance.
12 MP cameras without HDR mean that colored point clouds and Gaussian Splatting scenes will not match the visual quality of the Eagle. The latter uses 48 MP cameras with 8K HDR output. They will not reach the quality of the dual 16 MP 1-inch cameras with mechanical shutters of the SHARE S20 either. Where visual fidelity is important, such as virtual tours or presentation-quality Gaussian Splatting, this is an obvious downgrade. The same applies to real estate walkthroughs.
Who is the Raven actually for?
The Raven is definitely positioned as an entry-level device into the world of handheld LiDAR scanning. Its targets are:
For those moving from iPhone or iPad to LiDAR. If you have used Polycam, SiteScape, or Scaniverse with the built-in LiDAR on your phone and have hit the ceiling of what these tools can do, Raven represents a huge step forward. It improves in terms of range, scan volume, point density, and workflow. It also offers a price that doesn't require strict professional justification.
Enthusiasts, makers, and content creators who want to capture rooms, buildings, or outdoor environments for personal projects, game asset creation, Gaussian splatting experiments, or documentation are the ideal audience. The autonomous workflow and sub-$1,000 entry price make this scanner an almost impulse purchase. No other handheld LiDAR scanner has ever been this accessible.
Small businesses that want to explore virtual tours and spatial documentation can do so without having to purchase professional surveying equipment. Real estate agents, event venues, and renovation companies might find Raven to be a "sufficient" level of spatial acquisition for non-critical applications.
For professional surveyors, architects, or anyone involved in BIM/CAD: the Raven is likely not the right tool. The FJD Trion P2 offers 1.2 cm post-processed accuracy, multi-SLAM fusion, and HyperDense+ technology. It also includes 12 MP dual cameras and a proven FJD Trion software ecosystem. The SHARE S20 offers ≤1 cm relative accuracy and a confirmed Livox Mid-360 sensor. It also has dual 16 MP 1-inch cameras with mechanical shutters. The 3DMakerPro Hawk claims an accuracy of 1.5 cm at 10 m and 480,000 points/s with multi-echo LiDAR. It also offers an IP65 rating. All of these systems are significantly higher-performing than the Raven, albeit at correspondingly higher price points.
The conclusion
3DMakerPro Raven does something no other autonomous handheld LiDAR scanner has ever done. It makes the technology accessible for less than $1,000. The compromises are real and already documented. The LiDAR sensor has lower specifications and a narrower field of view. The detection range is reduced, and the cameras are simpler, without HDR. The software ecosystem is still maturing. However, the value proposition at this price is hard to ignore.
The question is not whether the Raven is better than a $4,000+ scanner. It is not. The real question is whether it is good enough to open the doors to a new generation of users. We are talking about people who would never have considered LiDAR scanning before. Based on the specifications, the price, and the expansion path, the answer is probably yes. However, it comes with the warning that you need to have realistic expectations. You have to consider software refinement and scan quality compared to established competition.

 https://www.instagram.com/3digital.tech/

